Nous-Girl: StackChan robot with Hermes Agent memory
The creator: @alexcovo_ethOriginal post
A talking StackChan desk robot with faces, DJ mode and an optional Hermes Agent brain
- Posted
- GitHub stars
- 35 (GitHub)
What you need
- Difficulty
- Intermediate · Our suggestion
- License
- MIT (tribute face excluded) (source)
Parts
- M5Stack StackChan K151 (CoreS3, ESP32-S3) (board)
- USB-C cable, A computer for the voice server (only macOS on Apple Silicon tested so far)
- AI model or service
- xiaozhi-esp32-server, Parakeet (MLX) speech-to-text, Phonon text-to-speech, Hermes Agent (optional), Cloud model or Ollama
Steps
- Difficulty
- Intermediate
- Back up the robot, then flash the current firmware (robot, boy or girl face)
- Point it at the official xiaozhi cloud, or start your own xiaozhi-esp32-server in Docker for DJ mode, memes, email and Hermes Agent
- Join the robot’s Xiaozhi-XXXX Wi-Fi from your phone and pick your 2.4 GHz home Wi-Fi
- Hold the screen 1.5 s > Server, enter your server address and restart
- Optional: set up Hermes Agent as the brain
- Say “Hey Nous-Girl”
Full instructions: View original
Like this build? Get the weekly builds
Every Thursday: the 5 best gadget hacks you can copy. Free.
Built something? Submit a build
Overview
Nous-Girl is open-source firmware (MIT; tribute face excluded) by Alex Covo for the M5Stack StackChan K151 (CoreS3, ESP32-S3). It talks back with animated faces and lip sync, answers to “Hey Nous-Girl”, lights 12 RGB LEDs, dances, and has DJ, camera and Actor modes. It runs end to end on the creator’s own robot and Mac, but the public builds are “not yet tested on hardware”.
What it does
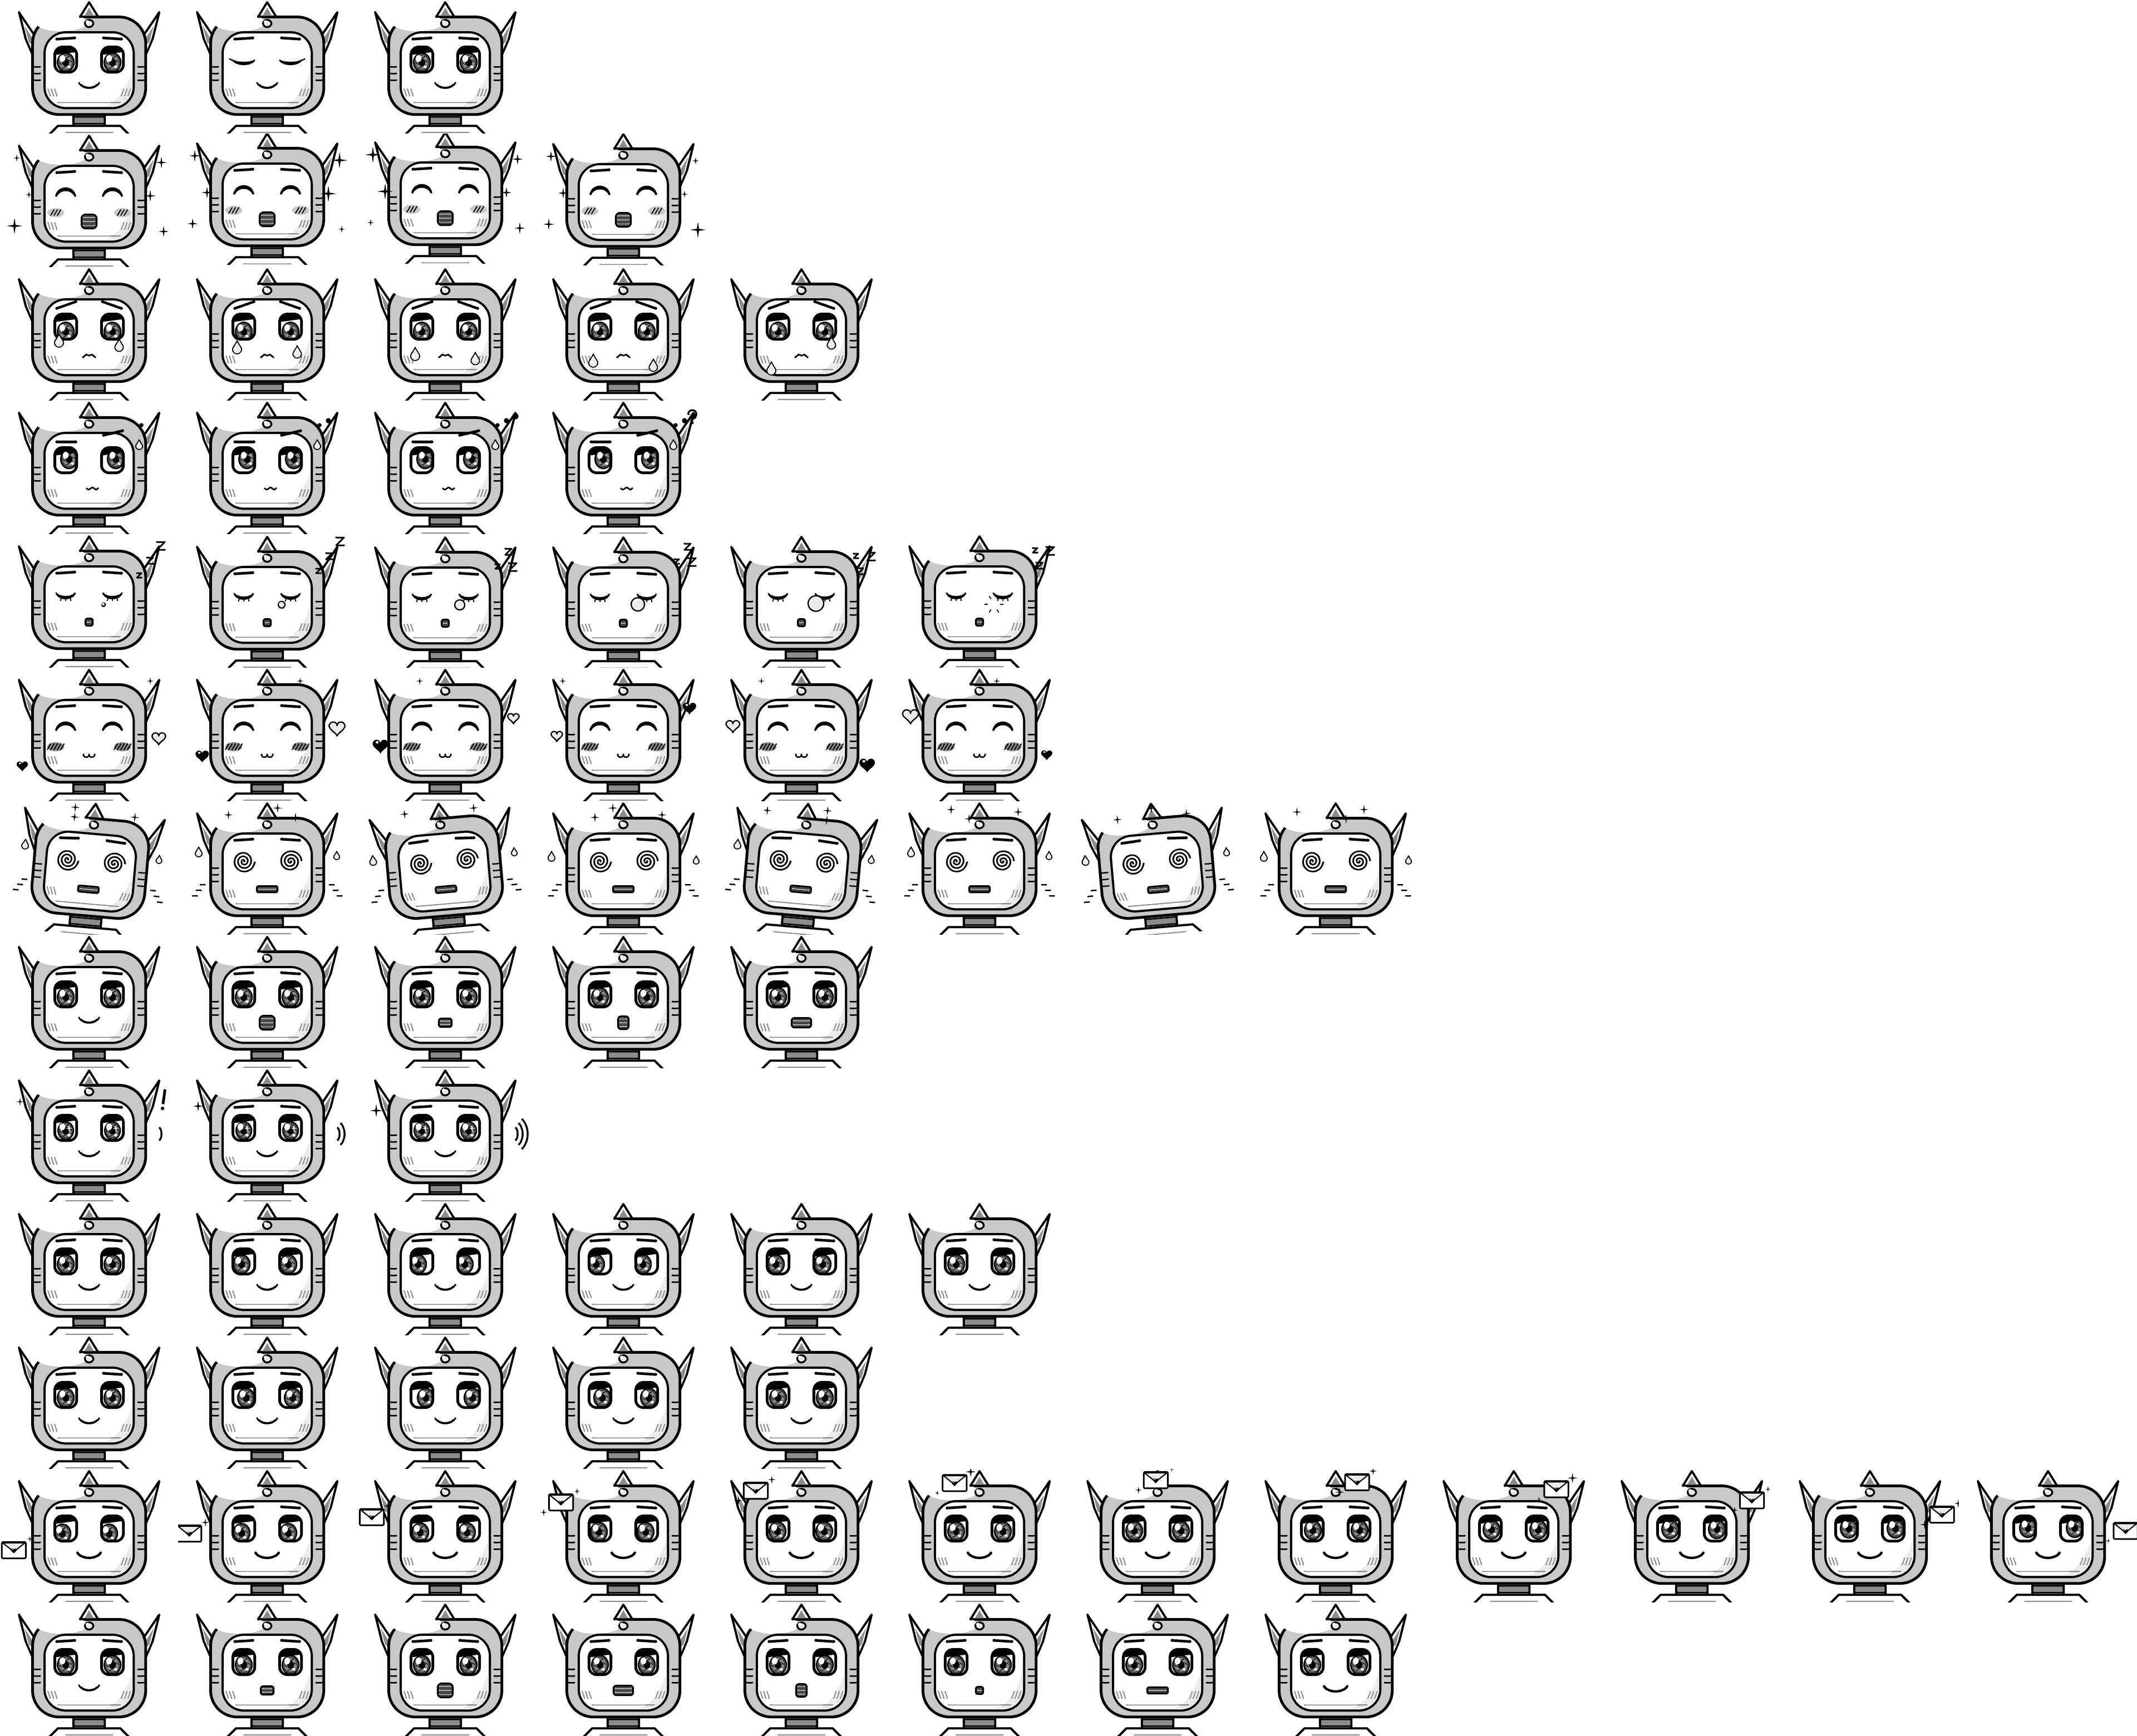
- Animated faces with lip sync and moods; three CC0 starter faces (robot, boy, girl), or make your own.
- Wake words “Hey Nous-Girl” and “Hey Jarvis”; tap the screen to stop it talking.
- 12 RGB LEDs, preset and recorded dances, and a 3-pad head sensor.
- Music, DJ mode and internet radio, with a live 13-band equalizer and beat-synced colors.
- Speaks English, Spanish, French, German and Portuguese, each with its own voice.
- Camera: “what do you see”, face ID, and following faces.
- Email from its own AgentMail inbox, read back and confirmed before sending.
Parts and requirements
- Computer for setup: A Windows, Linux or Mac computer to flash the robot and run the voice server; only macOS on Apple Silicon is tested so far
How it works
The robot runs custom xiaozhi-based firmware. On first boot you point it at a server: the official xiaozhi cloud works with no server of your own. Running your own xiaozhi-esp32-server in Docker on your computer adds DJ mode, memes, email and the Hermes Agent brain. There, Parakeet (MLX) turns speech into text, Phonon voice servers speak the replies, and the words go to Hermes Agent (long-term memory and tools) or straight to a model in Ollama.
| Layer | Component | Runs on |
|---|---|---|
| Robot | Nous-Girl firmware | StackChan K151 (ESP32-S3) |
| Voice server | xiaozhi-esp32-server, or the official xiaozhi cloud for first boot | Your computer (Docker) |
| Speech-to-text | Parakeet (MLX) | Your Mac |
| Text-to-speech | Phonon voice servers | Your computer |
| Brain A (hardest) | Hermes Agent + any model: long-term memory and tools | Your computer; model in the cloud or Ollama |
| Brain B (medium) | Hermes Agent + Ollama: long-term memory and tools | Your computer |
| Brain C (easiest) | Ollama only: no memory between conversations | Your computer |
Setup effort
The creator rates the brain setups from easiest (Ollama only) to hardest (Hermes Agent + any model).
Limits and caveats
- Beta with one maintainer: it runs end to end on the creator’s own robot and Mac, but the public builds are “not yet tested on hardware”.
- Firmware: v3.6.7-dj7 (prerelease); fallback dj5; avoid dj6 (it can reboot).
- First boot works with the official xiaozhi cloud; DJ mode, memes, email and Hermes Agent need your own server.
- Only macOS on Apple Silicon is tested so far for the voice server.
- The multilingual Phonon voice is CC-BY-NC-4.0 and gated: accept its terms, non-commercial use only.
- The Nous-Girl tribute face is fan art, not under the MIT license; public builds ship the CC0 starter faces.
- The patched firmware source for each version is not public yet; flash the release files.
Hardware
- M5Stack StackChan K151 (CoreS3, ESP32-S3)
- USB-C cable
- A computer for the voice server (only macOS on Apple Silicon tested so far)
Credits and links
- Alex Covo: Creator; drew the CC0 starter faces shown above
- M5Stack StackChan: Robot hardware
- xiaozhi-esp32: Upstream firmware
- xiaozhi-esp32-server: Voice server
- License: MIT (tribute face excluded) (source)
Sources
- github.com/dax8it/nous-girl-stackchan/blob/fe8b02342a382598de1faa5c9bc93144549ea9e9/README.md?plain=1#L44
- github.com/dax8it/nous-girl-stackchan/blob/fe8b02342a382598de1faa5c9bc93144549ea9e9/README.md?plain=1#L45
- github.com/dax8it/nous-girl-stackchan/blob/fe8b02342a382598de1faa5c9bc93144549ea9e9/README.md?plain=1#L46
- github.com/dax8it/nous-girl-stackchan/blob/fe8b02342a382598de1faa5c9bc93144549ea9e9/README.md?plain=1#L47
- github.com/dax8it/nous-girl-stackchan/blob/fe8b02342a382598de1faa5c9bc93144549ea9e9/README.md?plain=1#L48
- github.com/dax8it/nous-girl-stackchan/blob/fe8b02342a382598de1faa5c9bc93144549ea9e9/README.md?plain=1#L49
- github.com/dax8it/nous-girl-stackchan/blob/fe8b02342a382598de1faa5c9bc93144549ea9e9/README.md?plain=1#L52
- github.com/dax8it/nous-girl-stackchan/blob/fe8b02342a382598de1faa5c9bc93144549ea9e9/README.md?plain=1#L76
- github.com/dax8it/nous-girl-stackchan/blob/fe8b02342a382598de1faa5c9bc93144549ea9e9/README.md?plain=1#L69
- github.com/dax8it/nous-girl-stackchan/blob/fe8b02342a382598de1faa5c9bc93144549ea9e9/README.md?plain=1#L58-L70
- github.com/dax8it/nous-girl-stackchan/blob/fe8b02342a382598de1faa5c9bc93144549ea9e9/README.md?plain=1#L71
- github.com/dax8it/nous-girl-stackchan/blob/fe8b02342a382598de1faa5c9bc93144549ea9e9/README.md?plain=1#L72
- github.com/dax8it/nous-girl-stackchan/blob/fe8b02342a382598de1faa5c9bc93144549ea9e9/README.md?plain=1#L34
- github.com/dax8it/nous-girl-stackchan/blob/fe8b02342a382598de1faa5c9bc93144549ea9e9/README.md?plain=1#L35
- github.com/dax8it/nous-girl-stackchan/blob/fe8b02342a382598de1faa5c9bc93144549ea9e9/README.md?plain=1#L36
- github.com/dax8it/nous-girl-stackchan/blob/fe8b02342a382598de1faa5c9bc93144549ea9e9/README.md?plain=1#L56-L86
- github.com/dax8it/nous-girl-stackchan/blob/fe8b02342a382598de1faa5c9bc93144549ea9e9/README.md?plain=1#L5-L7
- github.com/dax8it/nous-girl-stackchan/blob/fe8b02342a382598de1faa5c9bc93144549ea9e9/VERSIONS.md?plain=1#L5-L8
- x.com/alexcovo_eth/status/2115689635158307269
- github.com/dax8it/nous-girl-stackchan/blob/fe8b02342a382598de1faa5c9bc93144549ea9e9/README.md?plain=1#L94
- github.com/dax8it/nous-girl-stackchan/blob/fe8b02342a382598de1faa5c9bc93144549ea9e9/README.md?plain=1#L120
- github.com/dax8it/nous-girl-stackchan/blob/fe8b02342a382598de1faa5c9bc93144549ea9e9/VERSIONS.md?plain=1#L177
This page is a short summary written by HardwareLab. Build steps, code and photos belong to the creator; follow “View original” for the full project.
Featured? Add this badge
Built this? Paste the badge into your README. It links back to this page.
Markdown
[](https://hardwarelab.dev/projects/nous-girl-stackchan/?utm_source=badge&utm_medium=referral&utm_campaign=launch_2w)HTML
<a href="https://hardwarelab.dev/projects/nous-girl-stackchan/?utm_source=badge&utm_medium=referral&utm_campaign=launch_2w"><img src="https://hardwarelab.dev/badge.svg" alt="Featured on HardwareLab" width="188" height="20"></a>Related builds
All 28 in Robots & Rovers
Jetson Orin Nano ROS 2 AMR
A ROS 2 robot with TensorRT vision, LiDAR and voice on a Jetson.
- Jetson Orin Nano 8GB
- Waveshare IMX219-120
- RPLIDAR C1
- +4 more
Advanced3
Vibe Watch
An M5Stack StopWatch as a wrist remote for AI coding agents.
- M5Stack StopWatch (ESP32-S3, round display)
Intermediate151
RICOH GR Live View Shooting
Hot-shoe remote on a StickS3.
- M5Stack StickS3 (ESP32-S3, 8 MB flash, 8 MB PSRAM)
- RICOH GR II, GR III/IIIx or GR IV
- 3D-printed hot-shoe adapter (STL and STEP in the repo)
- +1 more
Beginner · Our suggestion45
OpenCat / Petoi
OpenCatESP32 runs the OpenCat quadruped robotics framework on BiBoard, an ESP32-based development board for legged robots with up to 12 servos.
- Petoi kits
- ESP32 board
- servos
Intermediate · Our suggestion5.6K